Collision patterns and reporting blind spots in 971 California autonomous vehicle crash reports
Alam, M. S., Zhang, L., Li, J., Dou, F., Bazilinskyy, P.
Submitted for publication.
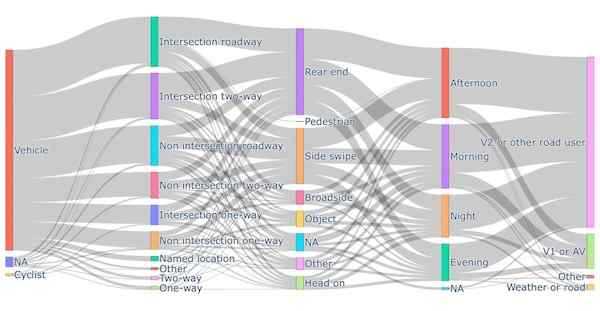
ABSTRACT Autonomous vehicle (AV) collision reports provide a rare public record of how autonomous driving systems behave in mixed traffic, but their value is limited by heterogeneous layouts, checkbox fields and free-text narratives. This work analyses 971 California Department of Motor Vehicles AV collision reports from October 2014 to March 2026 using a large language model based extraction pipeline and rule based post processing. The analysis identifies recurring scenario classes and evaluates what the reports make visible or leave underspecified. Three patterns dominate the corpus: rear-end collisions involving a stopped AV (267, 27.50%), intersection lateral conflicts (180, 18.54%) and lane-change or merge conflicts (156, 16.07%). The reports support broad scenario classification better than detailed interaction reconstruction: the mean coarse context score was 0.97, whereas the mean fine context score was 0.48. The largest blind spots concerned speed, lane position and traffic context. These findings suggest that many reported AV crashes occur in ordinary but interaction-heavy traffic situations where expectation, timing and coordination are difficult to align. preprintartificial-intelligencemetaautomated-driving